Stanford's Movement Lab Unveils HomeBody Humanoid Robot for Unfamiliar Kitchen Environments
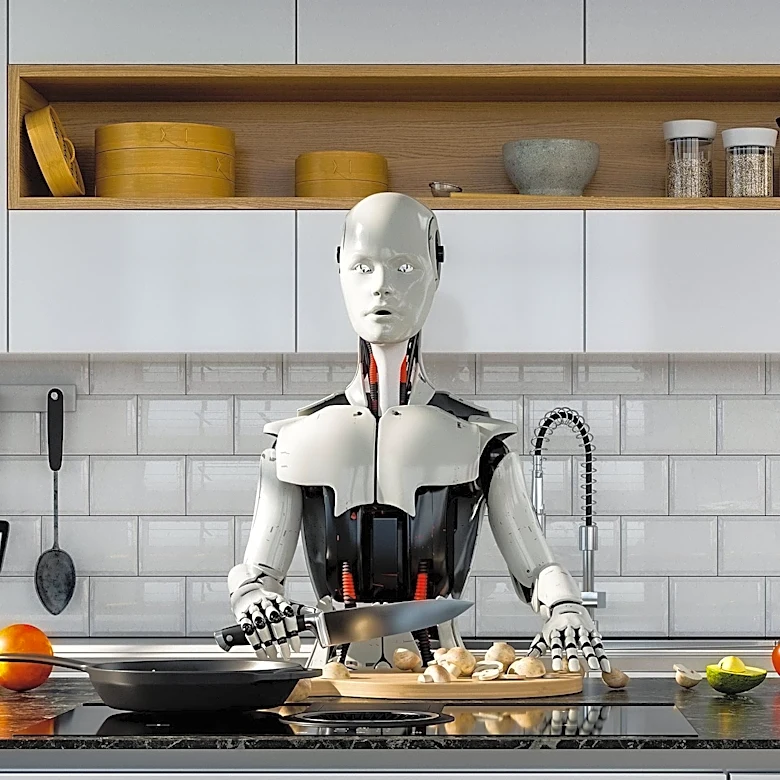
Stanford's Movement Lab has introduced HomeBody, a humanoid robot designed to operate in previously unseen kitchen environments. The robot achieves this by exploring the space, constructing a map, memorizing object locations, and executing commands such as tidying the kitchen or retrieving items from hidden drawers. A key design principle of HomeBody is its general-purpose AI model, which dictates actions and utilizes a library of skills for execution, including navigation, picking, placing, and opening drawers. This architecture allows for the reasoning model to be easily swapped out for newer, more advanced versions, while the skill library and the room's map retain their long-term value. The team behind HomeBody includes Gio Huh, Cayden Gu, Takara E. Truong, C. Karen Liu, and Guy Tevet from Stanford and Caltech. The system also incorporates a mechanism where skills can retry actions a limited number of times; if unsuccessful, they report back to the main model with a reason, allowing for plan adjustment...