MIT Researchers Develop SANDO, a Collision-Free Navigation System for UAVs in Unknown Dynamic Environments
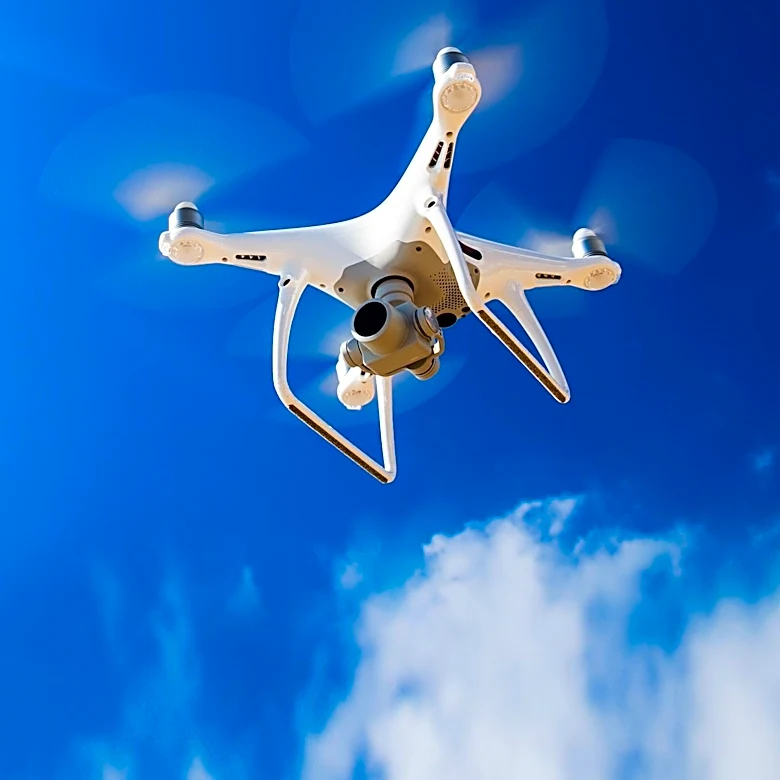
Researchers at the Massachusetts Institute of Technology (MIT) have developed a new autonomous navigation system for uncrewed aerial vehicles (UAVs) called SANDO (Safe AutoNomous trajectory planning for Dynamic unknOwn environments). This system is designed to ensure UAVs can navigate safely and avoid collisions in environments where obstacles are moving and the terrain is unfamiliar. Unlike previous systems that either handle static environments or loosely avoid dynamic obstacles without formal safety guarantees, SANDO provides a mathematical assurance that the UAV will not crash. The system works by mapping out a time-sensitive safety corridor, which accounts for the possible future movements of dynamic obstacles by calculating their maximum potential velocity. This allows the UAV to continuously adjust its flight path to remain collision-free. The research, led by Kota Kondo, a recent PhD graduate in aeronautics and astronautics at MIT, has been published in the IEEE Transactions on Robotics. SANDO has ...