
What's Happening?
Runway AI Inc. has released Praxis-1, its world action model for robotics, with open weights under the Apache 2.0 license. This model, a 27B-parameter mixture-of-experts diffusion transformer, is designed to predict video and actions together, enabling
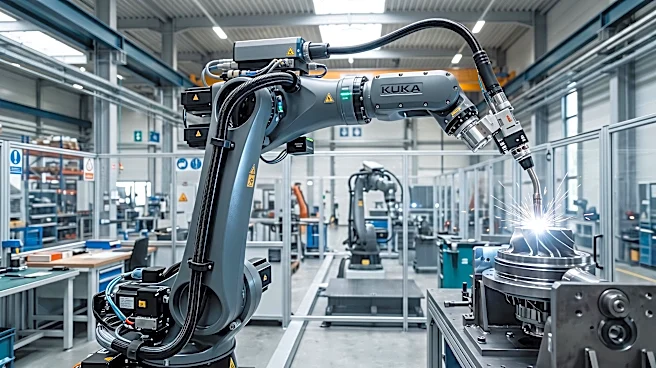
robots to understand the physical world and perform tasks. Praxis-1 has been tested by partners like Noble Machines, Standard Bots, and Ultra on various robot embodiments, including legged humanoids, six-axis industrial arms, and dual-arm warehouse robots. It has demonstrated strong performance, ranking as the top-ranked world action model on NVIDIA’s RoboLab leaderboard and the top-ranked open-source, end-to-end policy. The open-weight release allows developers to run, inspect, and adapt the model on their own hardware, including for commercial use.
Why It's Important?
The open-weight release of Runway AI's Praxis-1 model is a significant development for the U.S. robotics and artificial intelligence industries. By making the model accessible under an Apache 2.0 license, Runway is fostering innovation and collaboration among hardware developers, researchers, and companies. This move can accelerate the development and deployment of advanced robotics in various sectors, including manufacturing, logistics, and industrial automation, which are critical for boosting U.S. productivity and regaining global leadership in manufacturing. The flexibility for developers to adapt the model to diverse robot embodiments and tasks without extensive retraining reduces barriers to entry and speeds up the integration of AI into physical systems, potentially creating new economic opportunities and jobs.
What's Next?
Following the open-weight release, Runway AI plans to focus on scaling Praxis-1 deployments in real-world environments such as warehouses, factories, and industrial sites. This will involve continued collaboration with partners to gather real-world data and refine the model. The open-source nature of Praxis-1 is expected to lead to a surge in its adoption and adaptation by a wider community of developers, potentially resulting in novel applications and improvements. The availability of the model on platforms like GitHub and Hugging Face, with native LeRobot support, will facilitate its integration into various robotics projects. This could also spur further investment in both hardware and software development within the physical AI sector, driven by the increased interoperability and control offered by open world models.
Beyond the Headlines
The release of Praxis-1 with open weights carries deeper implications for the future of AI and robotics. It represents a strategic move by Runway AI to promote U.S. leadership in physical AI, emphasizing that regaining global manufacturing dominance and enhancing economic productivity will rely heavily on such advancements. The commitment to open weights challenges proprietary models by offering transparency and flexibility, which could become a standard for foundational AI models in robotics. This approach not only democratizes access to advanced AI capabilities but also encourages a more collaborative ecosystem, potentially leading to more robust, secure, and ethically developed robotic systems. The focus on real-world applications over lab-centric development suggests a pragmatic and impact-driven vision for AI's role in society.