


What's Happening?
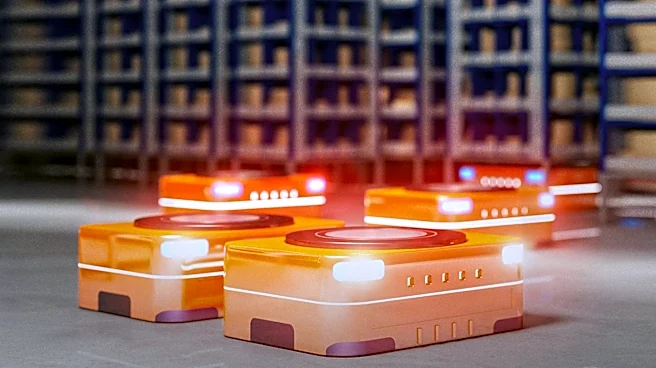
New research has introduced Multi-Agent Warehouse Pathfinding (MAWPF), an extension of the classical Multi-Agent Pathfinding (MAPF) problem, specifically designed to incorporate the complex kinodynamic constraints of Autonomous Guided Vehicles (AGVs)
in warehouse environments. This new framework addresses real-world challenges such as multi-step rotations, acceleration/deceleration, and a more conservative definition of collisions to improve safety. The study evaluates the performance of several lightweight MAPF solvers, including Prioritized Planning (PP), LNS2, PIBT, and LaCAM, when adapted to the MAWPF problem. The findings indicate that a rolling-horizon LaCAM+PIBT adaptation demonstrates the highest success rates, capable of managing hundreds of agents within seconds on benchmark tests. This suggests that the LaCAM+PIBT pipeline maintains a significant degree of scalability and real-time performance even with the added complexity of richer kinodynamic constraints.
Why It's Important?
The development of MAWPF is crucial for optimizing logistics and supply chain operations within the U.S. and globally, particularly in the rapidly expanding e-commerce sector. By more accurately modeling the movement of AGVs, this research can lead to more efficient and safer automated warehouses. Improved pathfinding algorithms can reduce operational costs, increase throughput, and minimize collisions, which are critical for businesses relying on large fleets of AGVs. Companies in manufacturing, retail, and distribution stand to gain significantly from these advancements, as they can deploy more sophisticated and reliable automation solutions. The ability to scale to hundreds of agents with high success rates means that even large-scale warehouse operations can benefit from these optimized pathfinding strategies, leading to a competitive advantage in a highly automated market.
What's Next?
Future research will focus on enhancing the solution quality and robustness of MAWPF algorithms, particularly in challenging layouts such as narrow corridors. This will involve developing more cost-aware successor generation methods and additional refinement mechanisms to address the limitations observed in such environments. The current practical limit of a few hundred agents for LaCAM in MAWPF, compared to thousands in classical MAPF, suggests a need for further optimization. Researchers will likely explore ways to reduce the computational cost of configuration generation and mitigate the impact of directed configuration graphs, which can lead to dead-end states and slow down high-level searches. These improvements could pave the way for lifelong MAWPF, enabling even larger-scale multi-agent systems through frequent replanning and incremental progress.
Beyond the Headlines
The introduction of MAWPF highlights a broader trend in artificial intelligence and robotics: the increasing demand for algorithms that bridge the gap between theoretical models and real-world operational complexities. This research underscores the ethical and safety implications of deploying autonomous systems, as the conservative collision definition in MAWPF aims to enhance safety in dynamic environments. The challenges encountered in scaling MAWPF to thousands of agents, despite the success of classical MAPF, reveal the inherent difficulties in integrating detailed physical constraints into AI planning. This work contributes to the ongoing evolution of industrial automation, pushing the boundaries of what autonomous systems can achieve in complex, dynamic settings and setting new standards for efficiency and safety in automated logistics.